Yuan Bi

Postdoctoral Researcher in Medical Robotics and AI
Boltzmannstr. 3, 85748 Garching bei München, Germany

I am a postdoctoral researcher at the Chair for Computer Aided Medical Procedures (CAMP), Technical University of Munich (TUM), Germany, where I lead the Robotics and Ultrasound (RobUSt) Team.

My research lies at the intersection of medical robotics, machine learning and imaging. The overarching goal is to develop intelligent and trustworthy robotic ultrasound systems that integrate perception, reasoning and action for both diagnostic and therapeutic applications.

I received my Ph.D. from TUM in 2026 under the supervision of Prof. Nassir Navab. Before that, I obtained my M.Sc. in Robotics, Cognition, Intelligence at TUM (2021) and my B.Eng. in Mechatronics at Tongji University, Shanghai, China (2018).

Portrait of Yuan Bi

research interests

Robotic Ultrasound Robot Learning Ultrasound Image Analysis Vision Language Models

news

Jul 24, 2026
Invited talk at the HIT Webinar.
Jun 23, 2026
2 papers and 1 live demo presented at the Hamlyn Symposium 2026, London, UK.
Jun 11, 2026
3 papers accepted to MICCAI 2026 (Strasbourg, France).
Jun 05, 2026
Best Poster Award at the IEEE ICRA 2026 Workshop RASEI.
May 27, 2026
Successfully defended my PhD thesis. Examiners: Prof. Nassir Navab, Prof. Alison Noble and Prof. Mahdi Tavakoli.
Apr 2026
Organizer of the Medical Augmented Reality Summer School 2026.
Mar 16, 2026
1 paper presented at the German Conference on Medical Image Computing.
Feb 17, 2026
1 paper accepted to Medical Image Analysis.
Feb 12, 2026
2 papers accepted to IPCAI 2026.
Jan 23, 2026
1 paper accepted to Scientific Reports.
Jan 10, 2026
Main organizer of the 4th Robotic-Assisted Medical Imaging workshop at ICRA 2026, Vienna, Austria.
Jul 14, 2025
1 paper accepted to Medical Image Analysis.
Jun 17, 2025
2 papers accepted to MICCAI 2025 (Daejeon, Korea).
Feb 27, 2025
Invited speaker at ORSI Surgical AI & Telesurgery Days, Ghent, Belgium.
Jan 16, 2025
1 paper accepted to IEEE Robotics and Automation Letters.
Oct 11, 2023
MI-SegNet received the MICCAI 2023 Best Paper Runner-up award.
Sep 01, 2021
Joined CAMP at the Technical University of Munich (TUM) as a Ph.D. student.

selected publications

full list on Google Scholar →

* equal contribution

Theme I — Autonomous Robotic Ultrasound

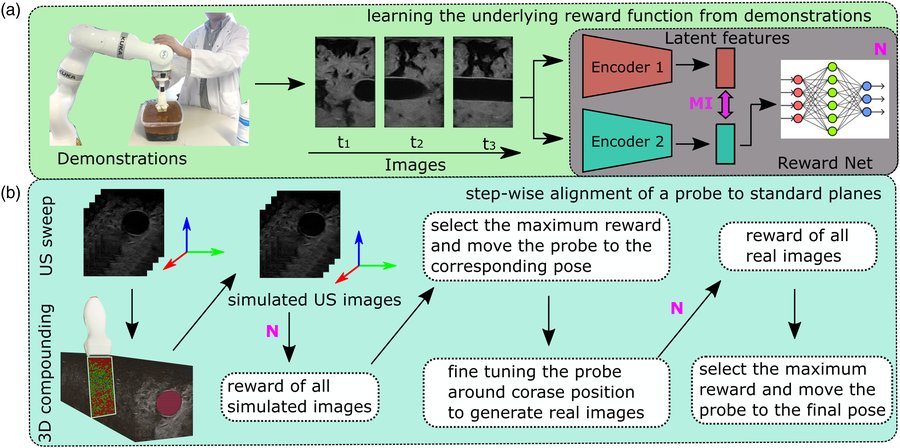
IJRR 2024 Overview figure: Intelligent Robotic Sonographer: Mutual Information-based Disentangled Reward Learning from Few Demonstrations

Intelligent Robotic Sonographer: Mutual Information-based Disentangled Reward Learning from Few Demonstrations

Zhongliang Jiang*, Yuan Bi*, Mingchuan Zhou, Ying Hu, Michael Burke, Nassir Navab
The International Journal of Robotics Research, 2024
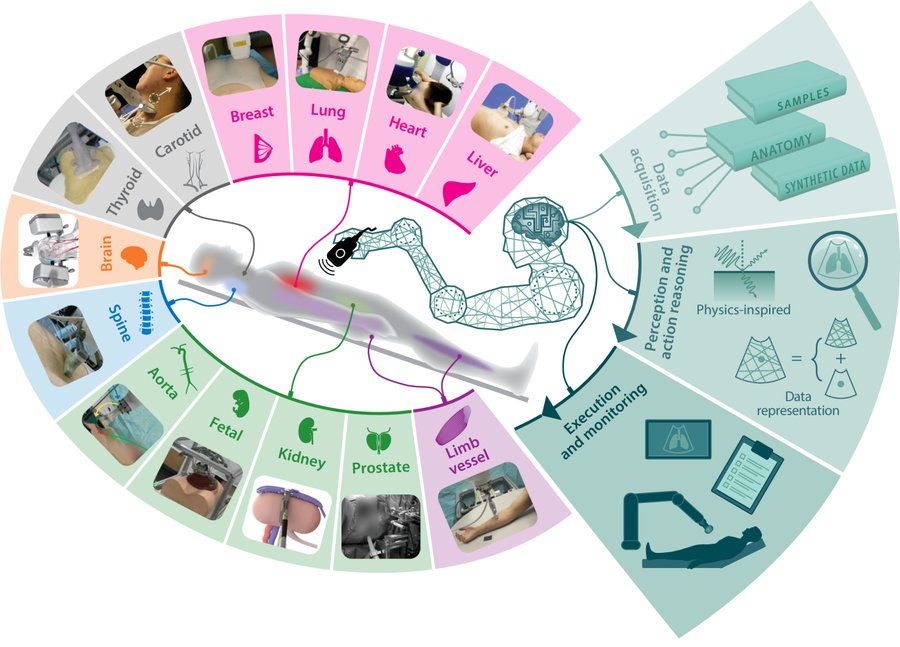
Annu. Rev. 2024 Overview figure: Machine Learning in Robotic Ultrasound Imaging: Challenges and Perspectives

Machine Learning in Robotic Ultrasound Imaging: Challenges and Perspectives

Yuan Bi*, Zhongliang Jiang*, Felix Duelmer, Dianye Huang, Nassir Navab
Annual Review of Control, Robotics, and Autonomous Systems, 2024
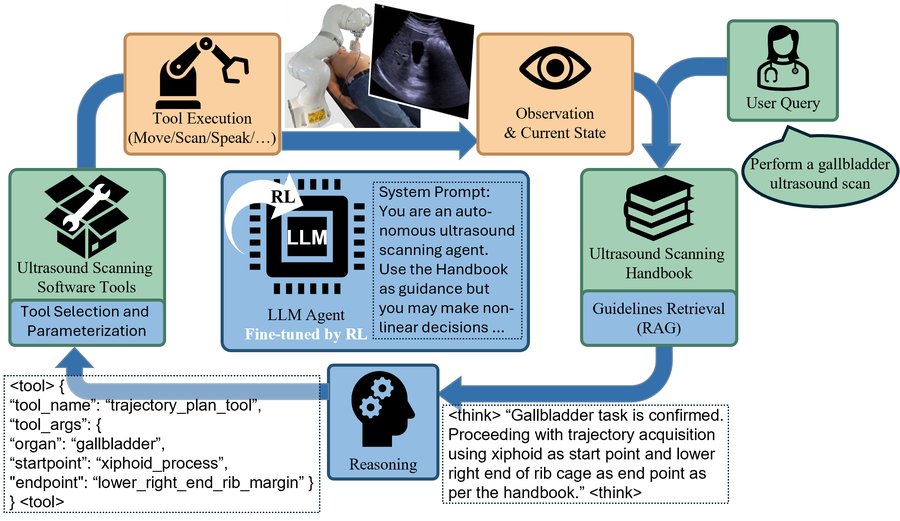
MICCAI 2026 Overview figure: From Scanning Guidelines to Action: A Robotic Ultrasound Agent with LLM-based Reasoning

From Scanning Guidelines to Action: A Robotic Ultrasound Agent with LLM-based Reasoning

Yuan Bi*, Yiping Zhou*, Pei Liu, Feng Li, Zhongliang Jiang, Nassir Navab
Medical Image Computing and Computer Assisted Intervention (MICCAI), 2026
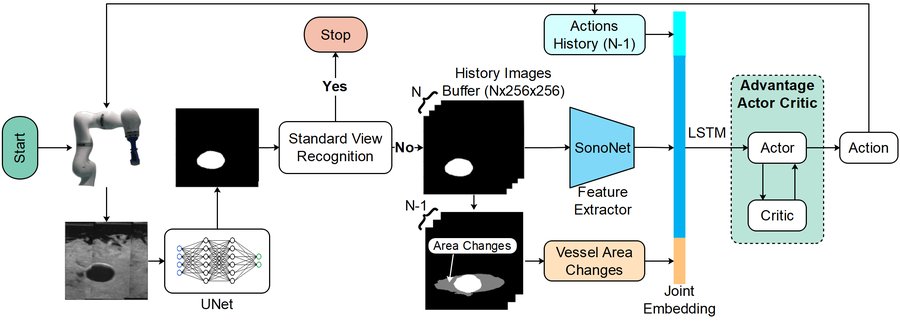
RA-L 2022 Overview figure: VesNet-RL: Simulation-based Reinforcement Learning for Real-World US Probe Navigation

VesNet-RL: Simulation-based Reinforcement Learning for Real-World US Probe Navigation

Yuan Bi*, Zhongliang Jiang*, Yuan Gao, Thomas Wendler, Angelos Karlas, Nassir Navab
IEEE Robotics and Automation Letters, 2022
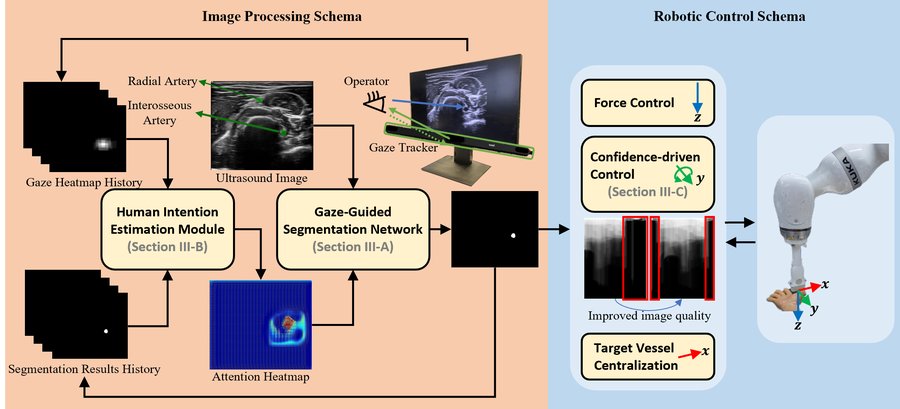
RA-L 2025 Overview figure: Gaze-Guided Robotic Vascular Ultrasound Leveraging Human Intention Estimation

Gaze-Guided Robotic Vascular Ultrasound Leveraging Human Intention Estimation

Yuan Bi, Yang Su, Nassir Navab, Zhongliang Jiang
IEEE Robotics and Automation Letters, 2025
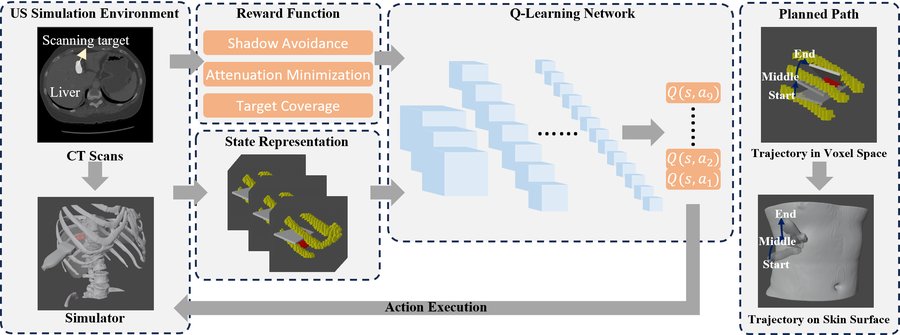
Sci. Rep. 2026 Overview figure: Autonomous Path Planning for Intercostal Robotic Ultrasound Imaging using Reinforcement Learning

Autonomous Path Planning for Intercostal Robotic Ultrasound Imaging using Reinforcement Learning

Yuan Bi*, Cheng Qian*, Zhicheng Zhang, Nassir Navab, Zhongliang Jiang
Scientific Reports, 2026

Theme II — Ultrasound Image Understanding

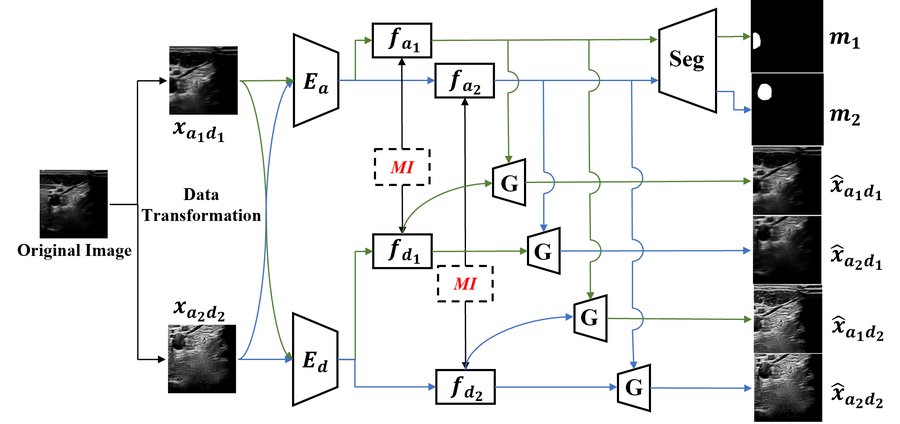
MICCAI 2023 Overview figure: MI-SegNet: Mutual Information-based US Segmentation for Unseen Domain Generalization

MI-SegNet: Mutual Information-based US Segmentation for Unseen Domain Generalization

Yuan Bi, Zhongliang Jiang, Ricarda Clarenbach, Reza Ghotbi, Angelos Karlas, Nassir Navab
Medical Image Computing and Computer Assisted Intervention (MICCAI), 2023
★ Best Paper Runner-up
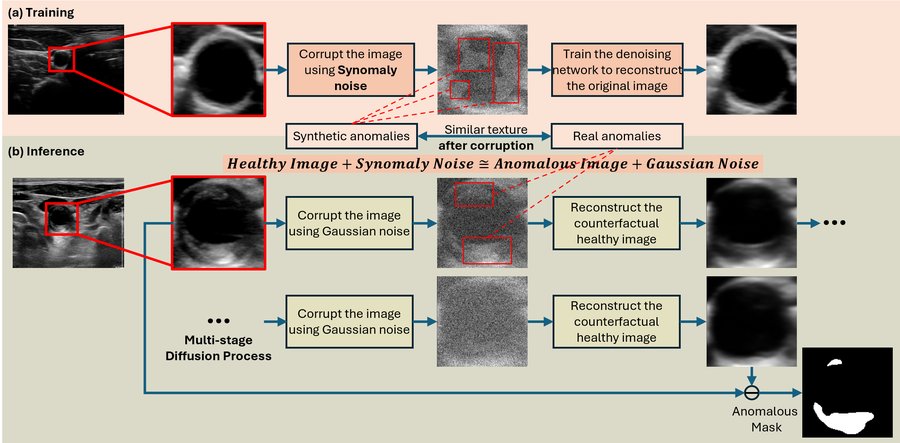
MedIA 2025 Overview figure: Synomaly Noise and Multi-Stage Diffusion: A Novel Approach for Unsupervised Anomaly Detection in Ultrasound Imaging

Synomaly Noise and Multi-Stage Diffusion: A Novel Approach for Unsupervised Anomaly Detection in Ultrasound Imaging

Yuan Bi*, Lucie Huang*, Ricarda Clarenbach, Reza Ghotbi, Angelos Karlas, Nassir Navab, Zhongliang Jiang
Medical Image Analysis, 2025
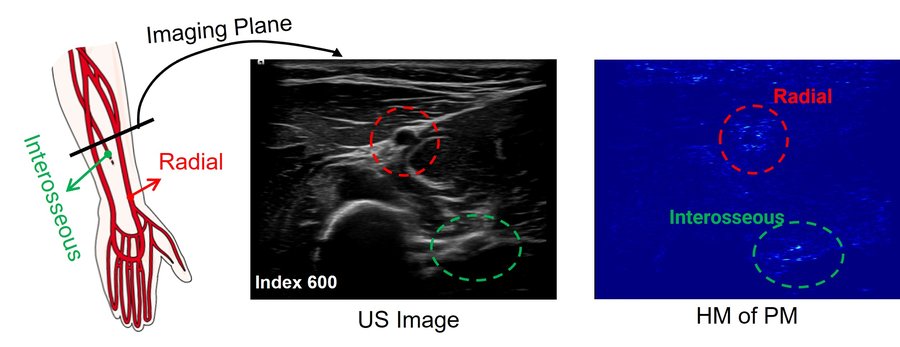
IROS 2023 Overview figure: Motion Magnification in Robotic Sonography: Enabling Pulsation-Aware Artery Segmentation

Motion Magnification in Robotic Sonography: Enabling Pulsation-Aware Artery Segmentation

Dianye Huang*, Yuan Bi*, Nassir Navab, Zhongliang Jiang
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023

cv

Sep 2025 – now
Postdoctoral Researcher, CAMP, TUM, Germany
Sep 2021 – May 2026
Ph.D. in Computer Science, TUM, Germany (advisor: Prof. Nassir Navab)
Oct 2018 – Jul 2021
M.Sc. in Robotics, Cognition, Intelligence, TUM, Germany
Sep 2014 – Sep 2018
B.Eng. in Mechatronics, Tongji University, Shanghai, China

awards

2026
Best Poster Award, IEEE ICRA 2026 Workshop (RASEI)
2023
Best Paper Runner-up, MICCAI 2023 (3 of 2,253 submissions)

supervised student projects

Year Type Title Student Outcome
2026Master ThesisIntelligent Agent-Guided Optimization of Ultrasound Imaging ParametersYingtai XuFinished
2026Master ThesisIntercostal Robotic Ultrasound Imaging Using Reinforcement LearningMustapha DalyFinished
2026Master ThesisFrom Freehand Demonstrations to Autonomous Robotic Ultrasound: An Anatomy-Anchored Learning FrameworkFangxu HanSubmitted to a journal
2026Master ThesisOrdinal Severity Modelling and Mitigation of an Age-Related Confound in Automated Detection of Severe Cerebral EdemaTim BruckdorferFinished
2026Master ThesisScanning While Imagining: A Scene-Graph World Model for Robotic Ultrasound NavigationShuai ChenSubmitted to a conference
2026Guided ResearchSurgOnAir: Hierarchy-Aware Real-Time Surgical Video CommentaryJingyi HeAccepted at MICCAI 2026
2026Master ThesisCounterfactual Flow: Unsupervised Anomaly Detection in 3D via Lesion InjectionYaxuan DaiSubmitted to a conference
2026Guided ResearchFrom Scanning Guidelines to Action: A Robotic Ultrasound Agent with LLM-Based ReasoningYiping ZhouAccepted at MICCAI 2026
2026Guided ResearchMask-to-Restore: Self-Supervised Ultrasound Despeckling via InpaintingYingtai XuSubmitted to a conference
2025Guided ResearchFrom Deterministic to Stochastic Synomaly: Multi-Stage Guided Diffusion for Generalizable Unsupervised Anomaly LocalizationYaxuan DaiSubmitted to a journal
2025Master ThesisInterpretable Ultrasound Video Captioning via Language-Supervised Visual GroundingCameron SimoleitFinished
2025Bachelor ThesisUnsupervised Anomaly Detection in Medical Imaging via Deformation Recovery ModelsSimon SeyfertFinished
2025Bachelor ThesisSteering-Angle-Controlled Robotic Ultrasound for Spinal ImagingLarissa ManalilAccepted at Hamlyn Symposium 2026
2025Master ThesisSystematic Auditing of Machine Unlearning for Large Language ModelsYueqi ZhangLock-LLM Workshop, NeurIPS 2025
2025Master ThesisSurrogate Modeling for Single NeuronsQilin ChenFinished
2024Master ThesisSynomaly Noise and Multi-Stage Diffusion: A Novel Approach for Unsupervised Anomaly Detection in Ultrasound ImagingLucie HuangPublished in Medical Image Analysis
2024Bachelor ThesisSimultaneous Tracking and Segmentation of Carotid PlaquesJason MannFinished
2024Master ThesisGaze-Guided Robotic Vascular Ultrasound Leveraging Human Intention EstimationYang SuPublished in IEEE RA-L
2023Guided ResearchAutonomous Path Planning for Intercostal Robotic Ultrasound Imaging Using Reinforcement LearningCheng QianPublished in Scientific Reports
2022Master ThesisTwo-Stage Deep Learning Framework for Plaque Segmentation in Carotid Ultrasound ImagesMoustafa ElsharkawyFinished

service & talks

Organizer

Invited talks

  • HIT Webinar, July 2026
  • ORSI Surgical AI & Telesurgery Days, Ghent, Belgium, Feb 2025